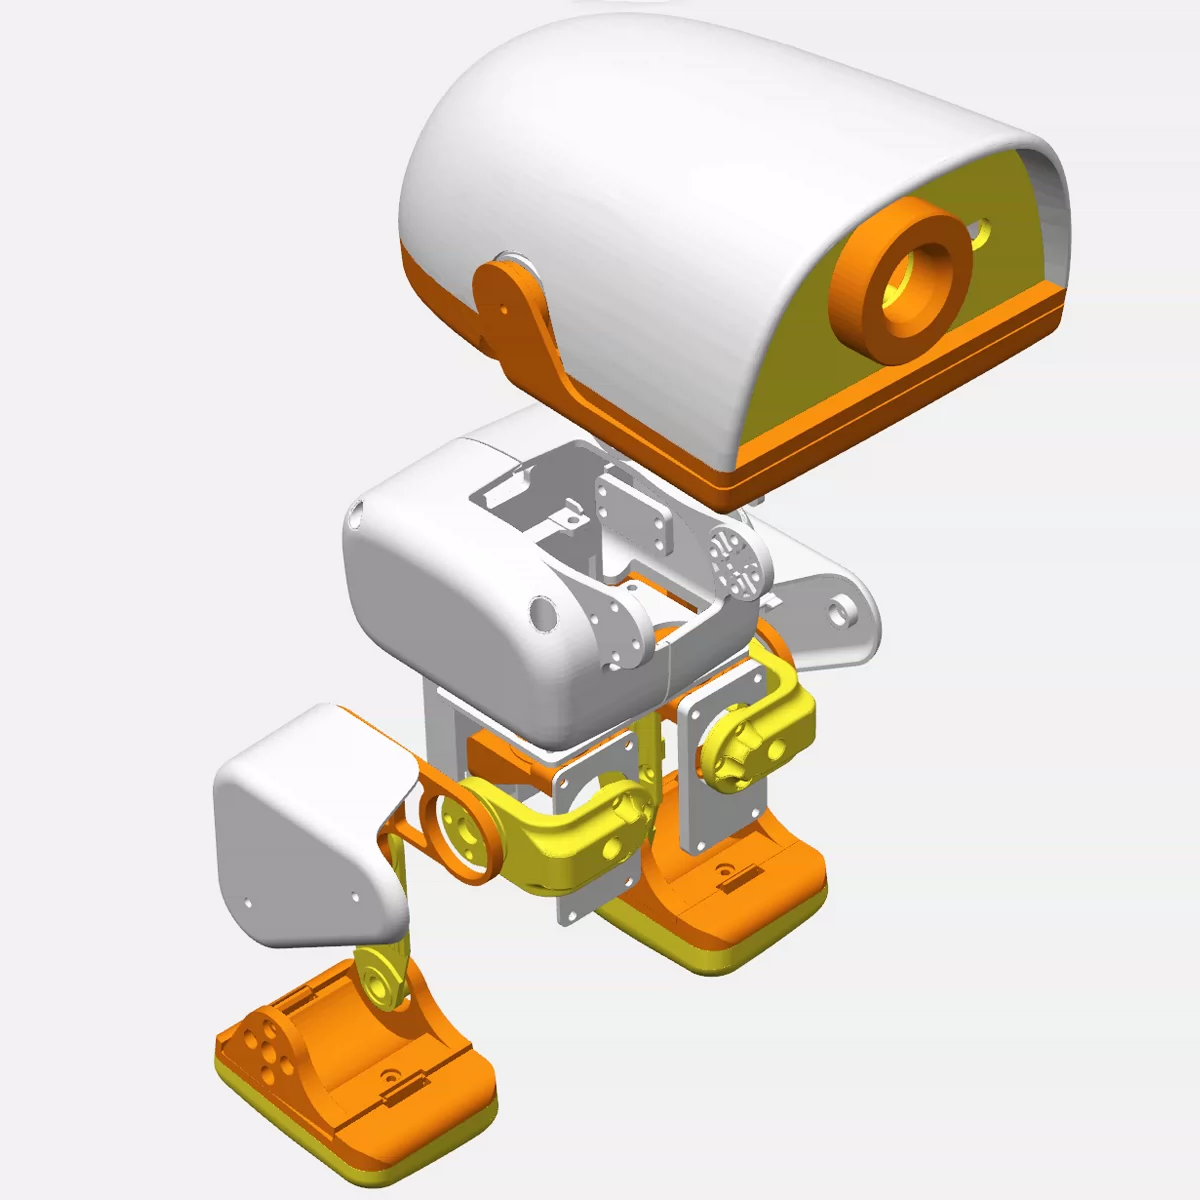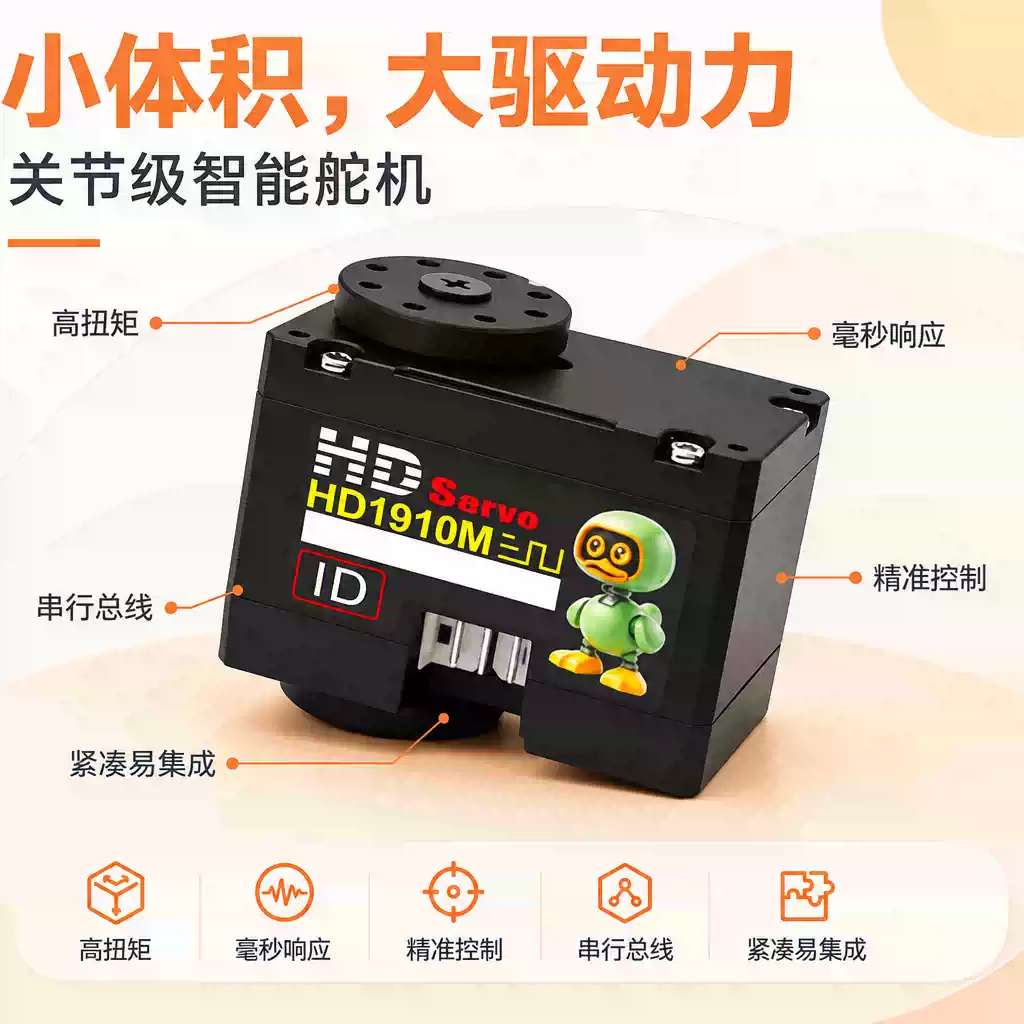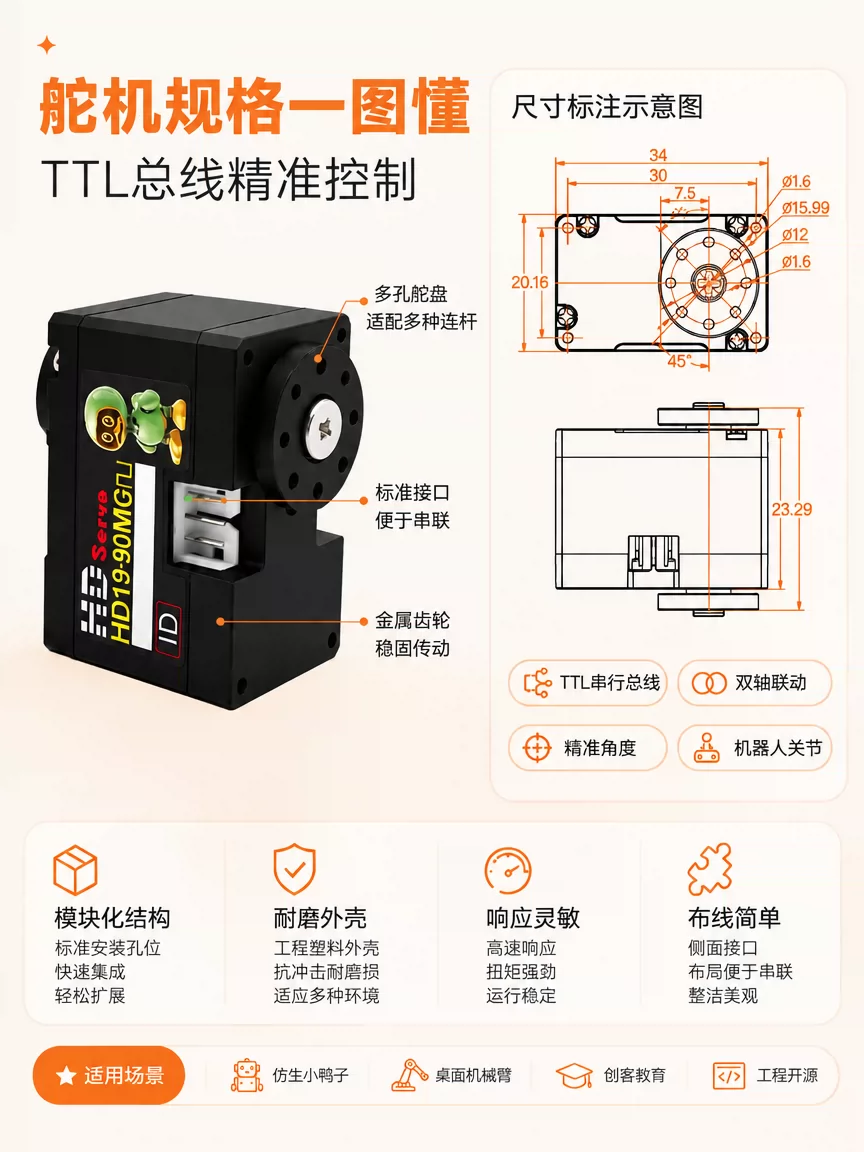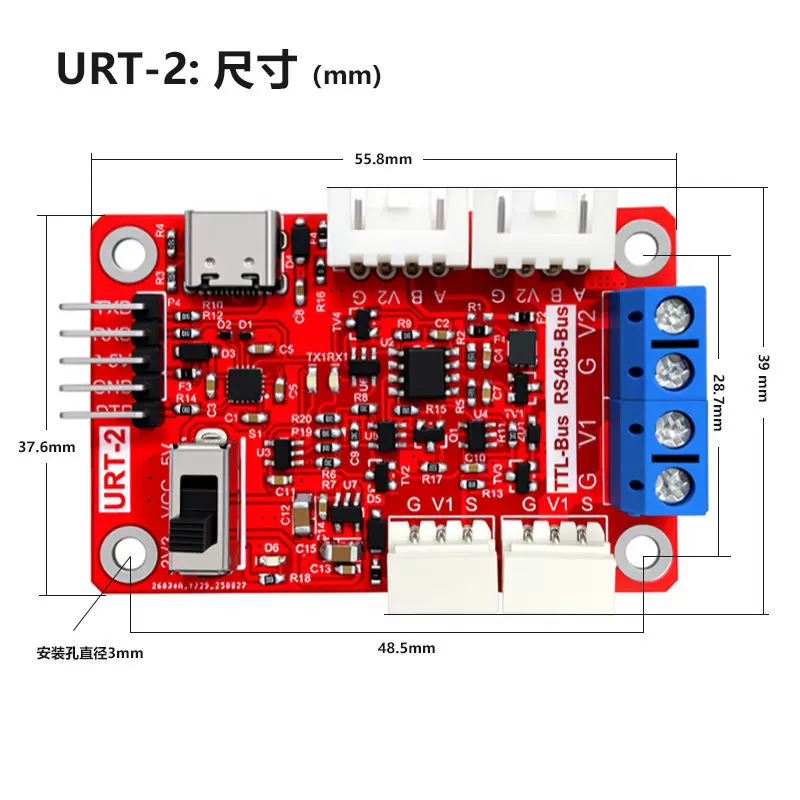

Concept illustration: internal shapes and positions are illustrative, not a repair guide. Select a number for component specifications and uses.
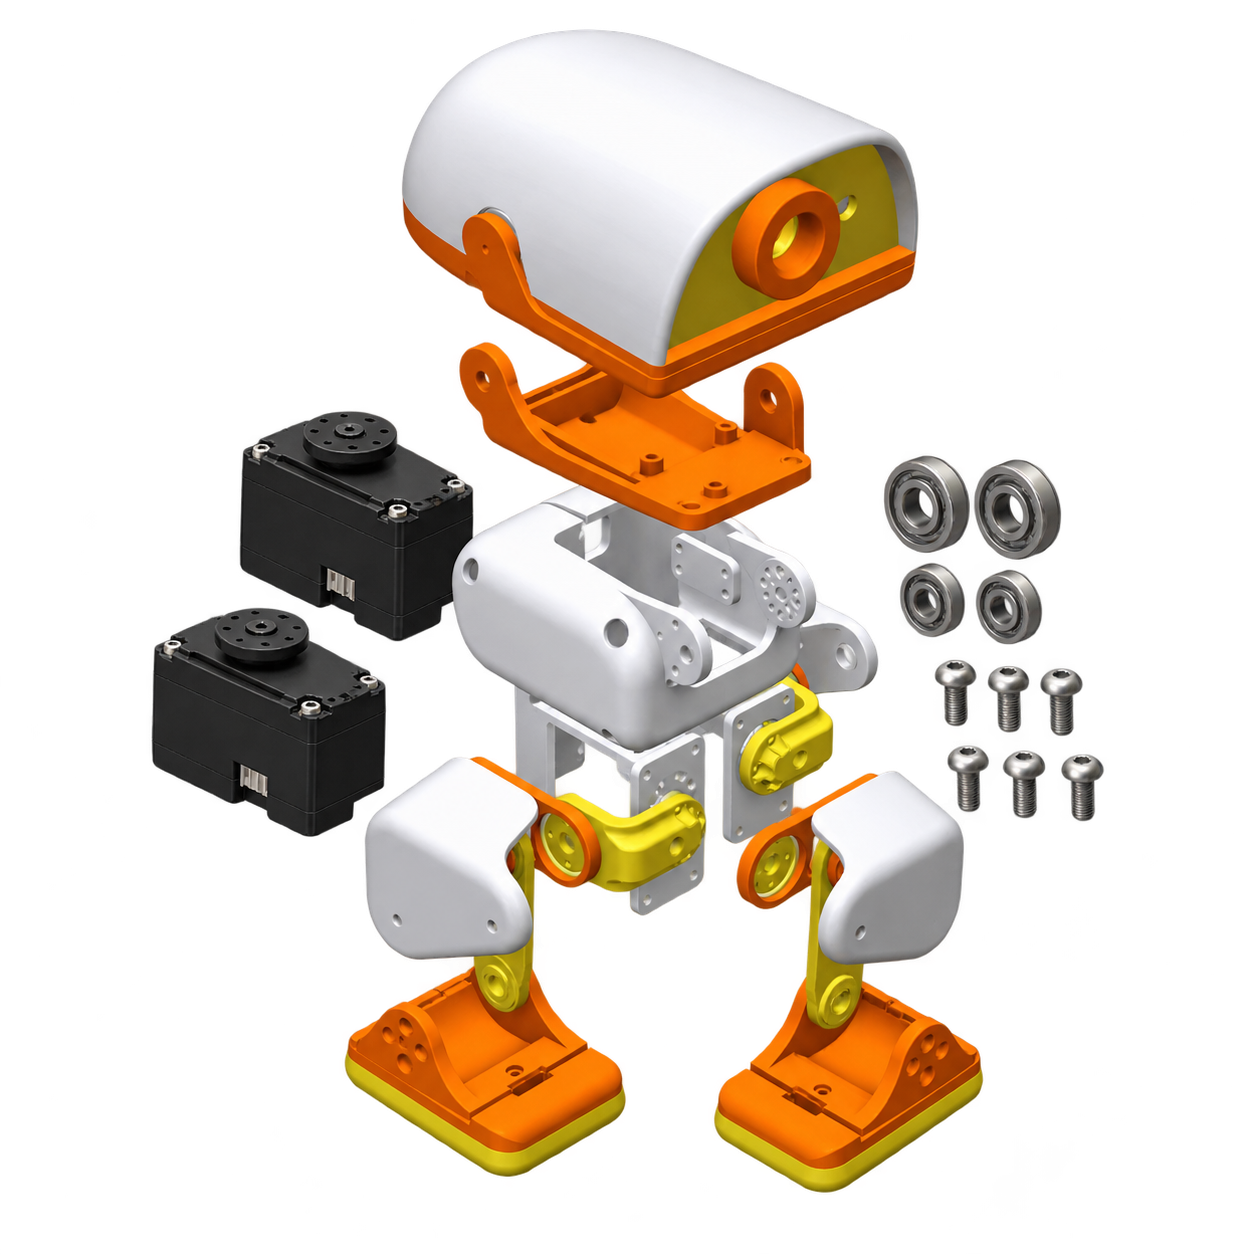
Printed head and frame
Printed structure groups; the head shape does not mean a camera is included.
Switch Style
WATCH / LEARN / USE
Videos, Manuals & FAQs
Assembly videos & project resources
Original maker videos and component documentation. Choose the HD1910 mechanical revision; project demonstrations may use electronics supplied separately.
01 Parts overview
Source: 机械行者Robo · Bilibili · 1:32. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
02 Lower leg assembly
Source: 机械行者Robo · Bilibili · 2:21. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
03 Upper leg assembly
Source: 机械行者Robo · Bilibili · 5:13. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
04 Torso assembly
Source: 机械行者Robo · Bilibili · 2:29. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
05 Neck assembly
Source: 机械行者Robo · Bilibili · 0:40. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
06 Head assembly
Source: 机械行者Robo · Bilibili · 5:50. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
OpenMicroDuck HD1910 training demonstration
Source: AI机器人极客 · Bilibili · 0:43. Copyright belongs to the original creator. Contact us for removal if this infringes your rights. Original video ↗ · Contact us
Videos play on this site. Original audio and on-screen text are retained; titles are translated for navigation.
Documentation, drawings & software
- HD-1910-C001 Feetech specification (8 pages)
- HD1910M dimensional drawing
- Robo maker assembly manual (21 pages, Chinese)
- HD1910 CAD, printing, component drawings & BOM
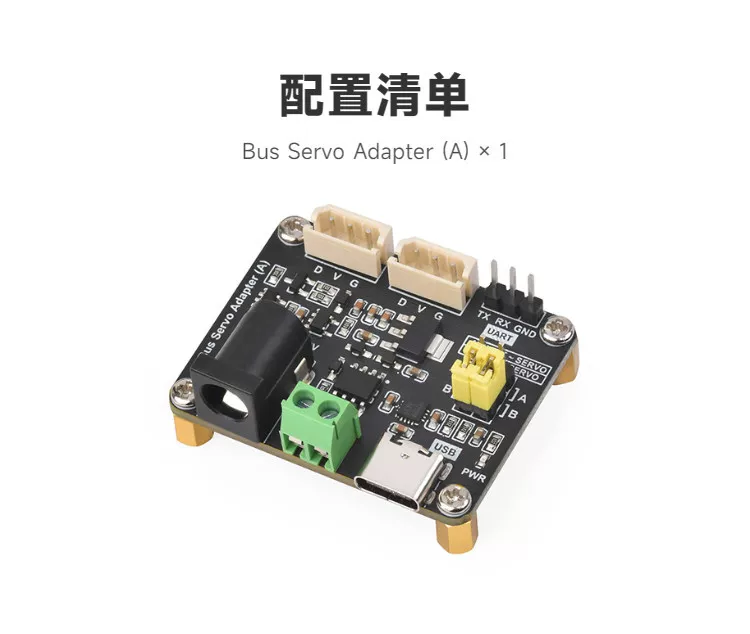
- Waveshare adapter A documentation & wiring
- OpenMicroDuck HD1910 structural differences
- Full project BOM (additional electronics)
- HD1910 servo setup and revision notes
- OpenMicroDuck software and training resources
- Raspberry Pi Camera Module 2 specifications
- Radxa ZERO 3 camera connection
Is this a ready-to-use complete robot?
No. The kit option is mechanical hardware and needs assembly plus a compatible control and power system. Choose individual parts separately when required.
Does every option include 15 servos?
Only the 15-servo kit does. Each other option supplies the selected individual part or part set.
Is a battery or controller included?
They are not listed in the USD400 kit contents. Do not infer included equipment from assembly or development renders.
Can I buy the camera?
Camera reference: OpenMicroDuck uses an IMX219/CSI route. Raspberry Pi Camera Module 2 uses an 8 MP IMX219 sensor (3280 x 2464); Radxa documents this module for ZERO 3. The project BOM also lists 5 MP, conflicting with the manufacturer specification. These references do not identify the unconfirmed camera sold here. Confirm the controller, module part number, ribbon pin count/orientation/pitch and mounting before ordering; connect with power off and never plug CSI into a servo TTL port. Price is not confirmed; contact support first.
Where is the manual?
Use View User Guide below the media resources for the ten-chapter Zoowai beginner guide and bilingual PDF. The resource panel also links the maker’s assembly manual, videos, servo specification and board documentation; match the hardware revision before use.
COMMUNITY
Reviews & shares
Experiences and everyday moments from the product community.
Reviews are updating. Refresh shortly, or view all reviews in the community.
PRODUCT DATA SHEET
Product Data Sheet
Specifications and support details are based on the product’s verified source information.
Product Identity
- Name
- Microduck HD1910 DIY Robot Kit
- Kit contents
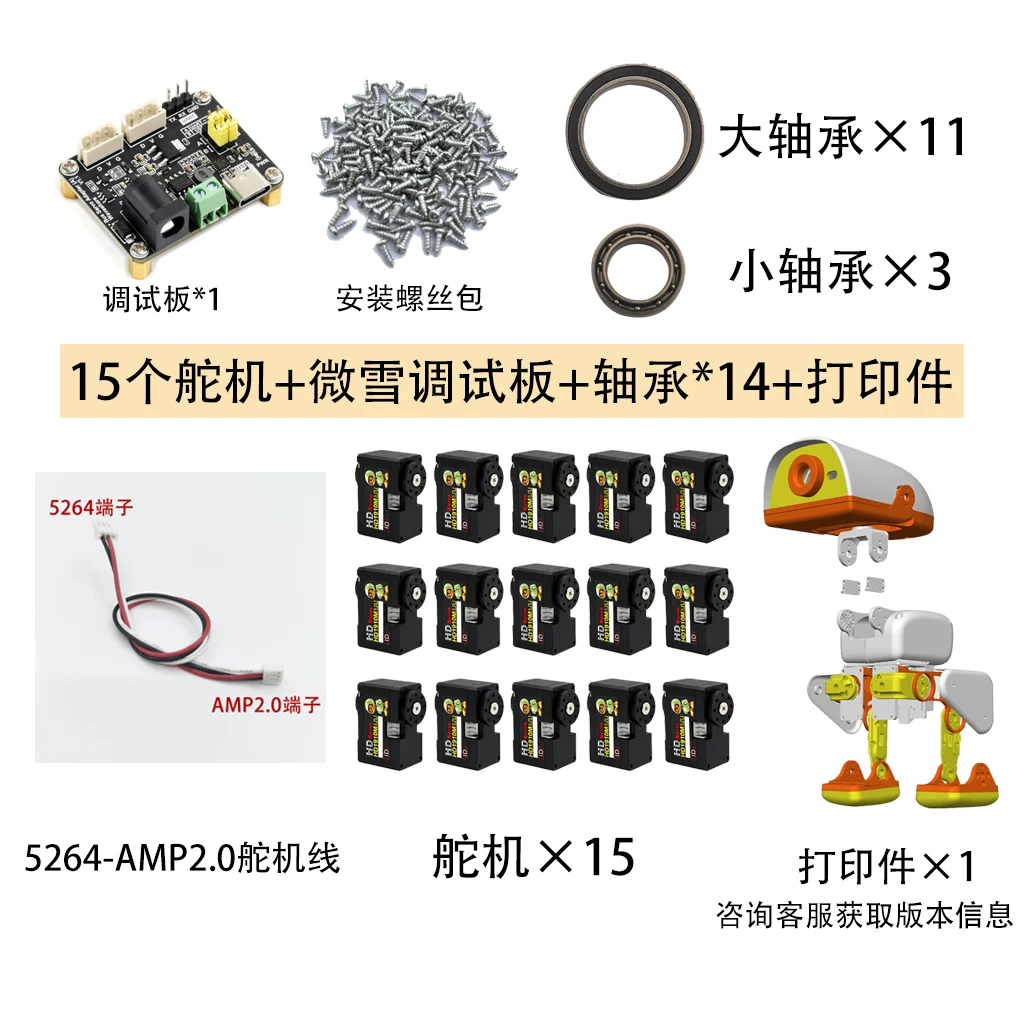
- 15 HD-1910-C001 servos, Microduck printed parts, an M2 mounting screw pack, 14 bearings (11 large + 3 small), a Waveshare bus-servo adapter/debug board and a 5264-AMP2.0 servo cable.
Specifications
- Servo model
- HD-1910-C001, specification A/0 (2026-09-07)
- Servo supply
- 4–8.4V; the adapter board voltage label does not permit 12V on this servo
- Stall torque
- 12 kg·cm at 6V; not continuous rated torque
- Rated load
- 3 kg·cm at 6V
- No-load speed
- 0.109 s/60° at 6V (92 rpm, ±10% specification tolerance)
- Stall current
- 1.6A at 6V per servo
- Case dimensions
- 34 x 20 x 23 mm; see drawing for shaft and mounting dimensions
- Servo weight
- 21±2g
- Position sensing
- 12-bit magnetic encoder; 4096 positions; 0.088° per pulse
- Communication
- TTL half-duplex asynchronous serial; 38400 bps–1 Mbps, 1 Mbps default
- Connector
- AMP2.0-3P; use the model-specific pin definition
- Waveshare adapter A
- 42 x 33 mm; CH343 USB serial; maximum 5A; no regulator, output equals input
Package & Support
- Warranty
- 1 year for non-user-caused faults; other repairs chargeable; customer pays repair shipping.
- Guide
- Zoowai compiled beginner edition; not an original complete-robot manual.
After-sales Policy
A one-year warranty covers non-user-caused damage. For user-caused damage or repairs outside the warranty period, please contact customer service to arrange paid repairs. Shipping costs for repairs are the customer's responsibility.
FROM COMPONENTS TO CREATIONS
Finished builds
See what you can build with this component. Contact us for complete builds or custom designs.
Assembled Microduck robot
Source: AI机器人极客 / OpenMicroDuck training demo. Additional electronics are required; the demo does not imply this kit is supplied as a tuned complete robot.
Assembly guide ↗MECHANICS / MOTION / LEARNING
A small biped, a hands-on project.
The USD400 option includes 15 HD-1910-C001 servos, Microduck printed parts, an M2 mounting screw pack, 14 bearings (11 large + 3 small), a Waveshare bus-servo adapter/debug board and a 5264-AMP2.0 servo cable. Assembly and a separate controller, camera, IMU, storage and power system are required. Individual options supply only their listed parts. The scene card shows a separated structure; this is an HD1910 DIY kit, not a Pollen Robotics complete robot. Camera reference: OpenMicroDuck uses an IMX219/CSI route. Raspberry Pi Camera Module 2 uses an 8 MP IMX219 sensor (3280 x 2464); Radxa documents this module for ZERO 3. The project BOM also lists 5 MP, conflicting with the manufacturer specification. These references do not identify the unconfirmed camera sold here. Confirm the controller, module part number, ribbon pin count/orientation/pitch and mounting before ordering; connect with power off and never plug CSI into a servo TTL port.